Automation Department
Autonomy, Control & Intelligence Systems
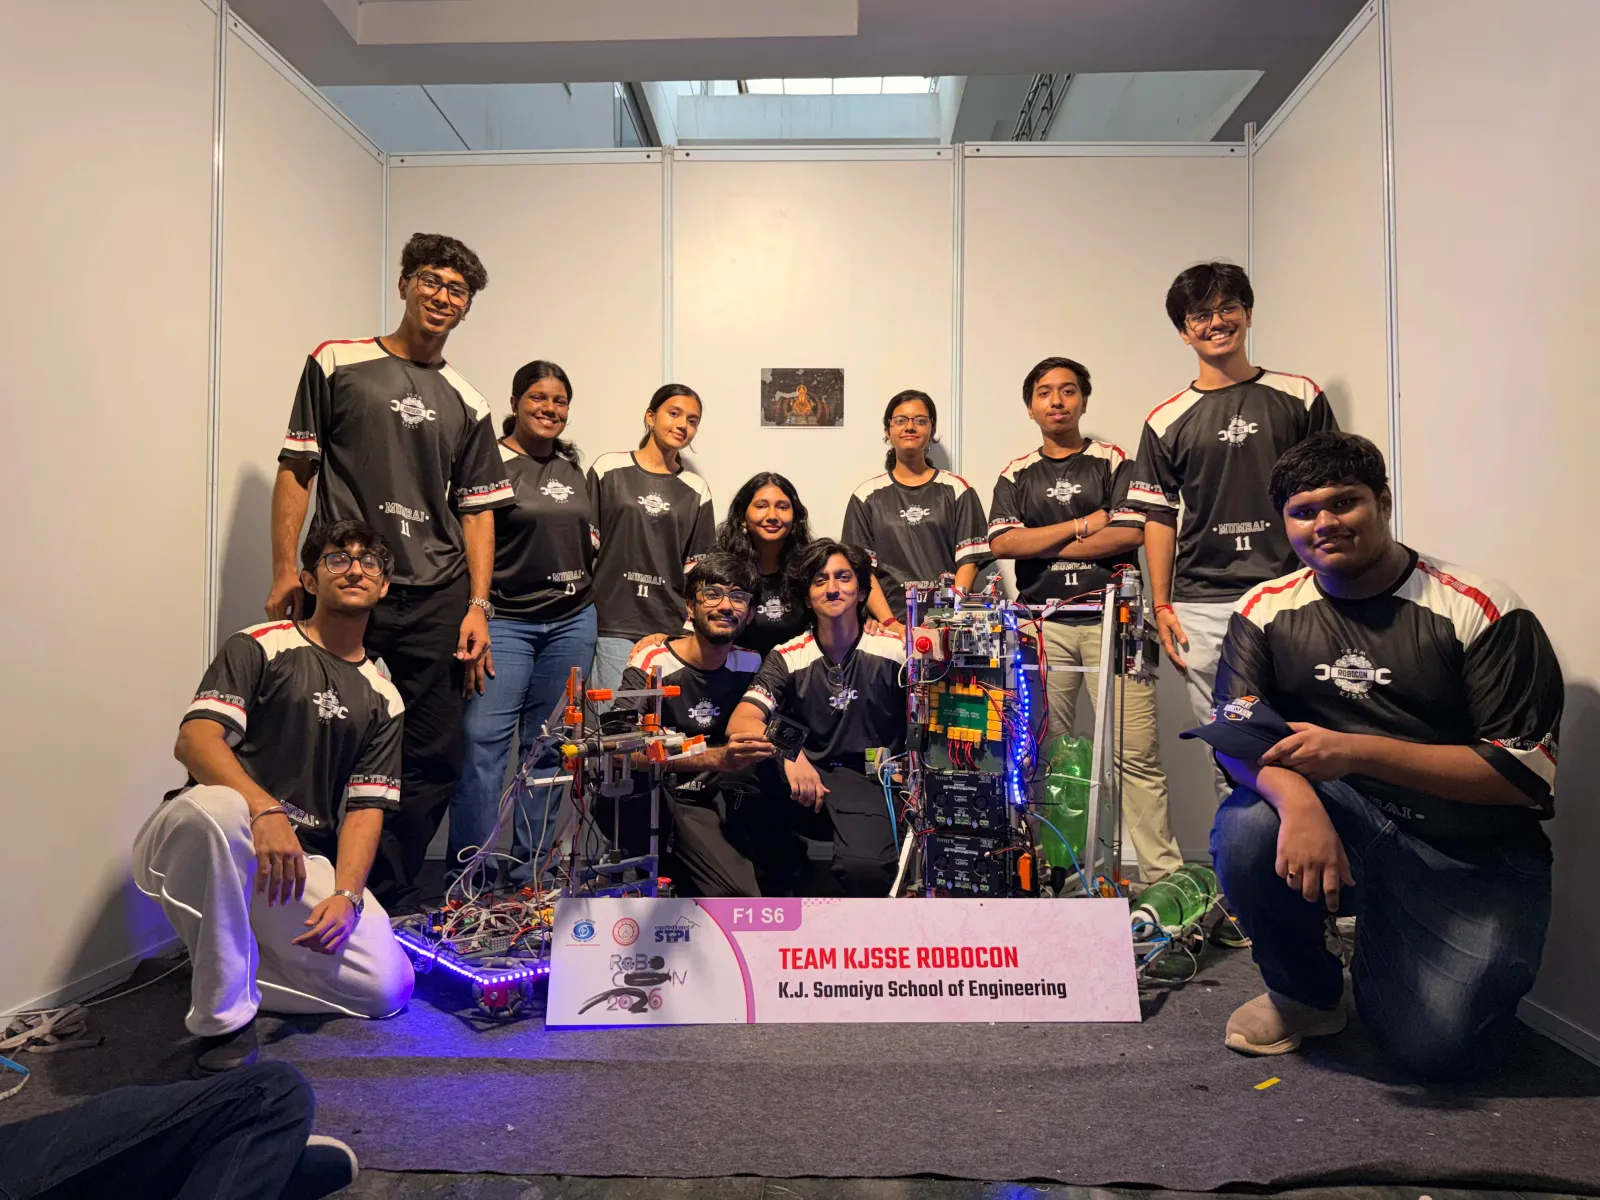
Autonomy, Control & Intelligence Systems
Algorithms that let robots decide where to go and how to get there — route planning, obstacle avoidance and autonomous positioning in dynamic competition arenas.
PID loops, state machines and closed-loop control that turn perception into precise motion — keeping every actuator, motor and mechanism on target in real time.
Cameras, LiDAR, encoders and IMUs combined into one coherent picture of the world — calibrated, synchronized and fused into reliable state estimates.
Computer vision for object detection and tracking, feeding on-board decision systems that choose the robot's next move — lines, markers, targets and terrain, interpreted in milliseconds.
Camera-driven navigation stack that fuses visual detection of lines and markers with path planning and obstacle avoidance for fully autonomous arena runs.
Kalman-filter pipelines that merge encoders, IMU and vision into a single trusted position estimate — the difference between thinking you know where you are and knowing.
End-to-end autonomous task sequences for competition rounds — perception triggers, decision logic and actuator control choreographed into reliable mission execution.
MATLAB/Simulink modeling of motor controllers and mechanism dynamics — simulated, tuned and validated before a single line runs on hardware.
Automation Co-Head
Automation Co-Head
Member
Member
Member
Member
Member
Member
Member
Member
Junior Member